About
I am a PhD student at HKUST(GZ), advised by Prof. Renjing Xu and Prof. Haoang Li. My research focuses on dexterous robot manipulation and embodied intelligence.
Previously, I obtained my M.Sc. from Harbin Institute of Technology (Shenzhen), advised by Prof. Xiaogang Xiong, focusing on robotic visual-tactile perception and reinforcement learning. I received my B.Eng. from Sichuan University (Elite Engineer Program, ranked 2/117).
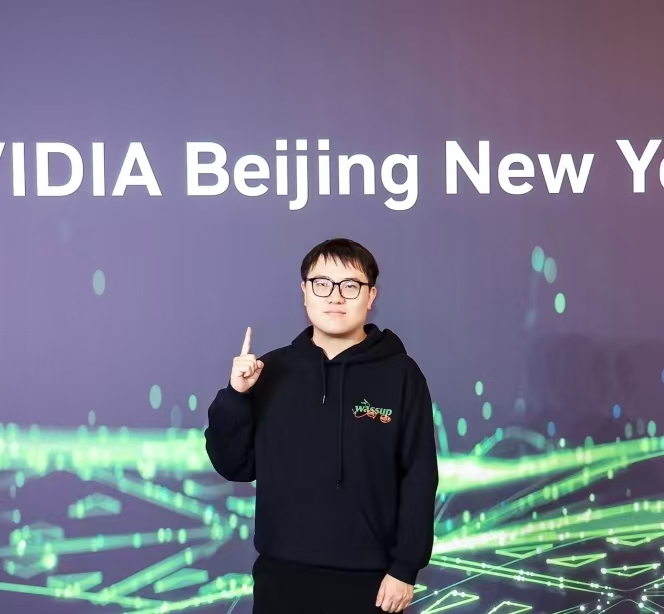
During my internship at NVIDIA China Robotics Team (2025.08–2026.08), I explored tactile sensing and Vision-Language-Action (VLA) models for robot manipulation, with work accepted at ICML. At Sony R&D Center China, I served as a reinforcement learning simulation engineer, building robotic arm digital twins in IsaacLab.
My research interests include dexterous robot manipulation, visual-tactile perception, embodied AI foundation models, and sim-to-real transfer for humanoid robots.
Selected Publications
View All →Tabero: Learning Gentle Manipulation with Closed-Loop Force Feedback from Vision, Touch, and Language
Qiwei Wu, Rui Zhang, Xin Xiang, Tao Li, Weihua Zhang, Junjie Lai, Renjing Xu
Proceedings of the 43rd International Conference on Machine Learning (ICML)
First author
Iterative Closed-Loop Motion Synthesis for Scaling the Capabilities of Humanoid Control
Weisheng Xu†, Qiwei Wu†, Jiaxi Zhang, Jing Tan†, Yangfan Li, Yuetong Fang, Jiaqi Xiong, Kai Wu, Rong Ou, Renjing Xu
Proceedings of the IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR)
Co-first author (*equal contribution)
Gentle Manipulation Policy Learning via Demonstrations from VLM-Planned Atomic Skills
Jiayu Zhou†, Qiwei Wu†, Jian Li, Zhe Chen, Xiaogang Xiong, Renjing Xu
Proceedings of the AAAI Conference on Artificial Intelligence (AAAI-26)
Oral presentation (Top 5%). Co-first author (*equal contribution)
TARS: Tactile Affordance in Robot Synesthesia for Dexterous Manipulation
Qiwei Wu, Haidong Wang, Jiayu Zhou, Xiaogang Xiong, Yunjiang Lou
IEEE Robotics and Automation Letters (RA-L)
First author. JCR Q1 Top
RTTF: Rapid Tactile Transfer Framework for Contact-Rich Manipulation Tasks
Qiwei Wu, Xuanbin Peng, Jiayu Zhou, Zhuoran Sun, Xiaogang Xiong, Yunjiang Lou
Proceedings of the IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)
First author
News
OHP-RL accepted at IEEE RA-L
HumanoidArena accepted at NeurIPS 2026
Completed my VLA research internship at NVIDIA China Robotics Team
Won ICRA WBCD Bimanual Manipulation Challenge in Vienna 🏆
Tabero accepted at ICML 2026 (first author)
Paper on humanoid control accepted at CVPR 2026 (co-first author)
Gentle Manipulation of Long-Horizon Tasks published in IEEE RA-L (co-first author)
Paper accepted at AAAI 2026 as Oral (Top 5%) (co-first author)
Joined NVIDIA China Robotics Team as VLA research intern
Started PhD at HKUST(GZ) with Prof. Renjing Xu and Prof. Haoang Li
Rapid Tactile Transfer paper accepted at IROS 2024 (first author)
Joined Sony R&D Center China as RL simulation engineer